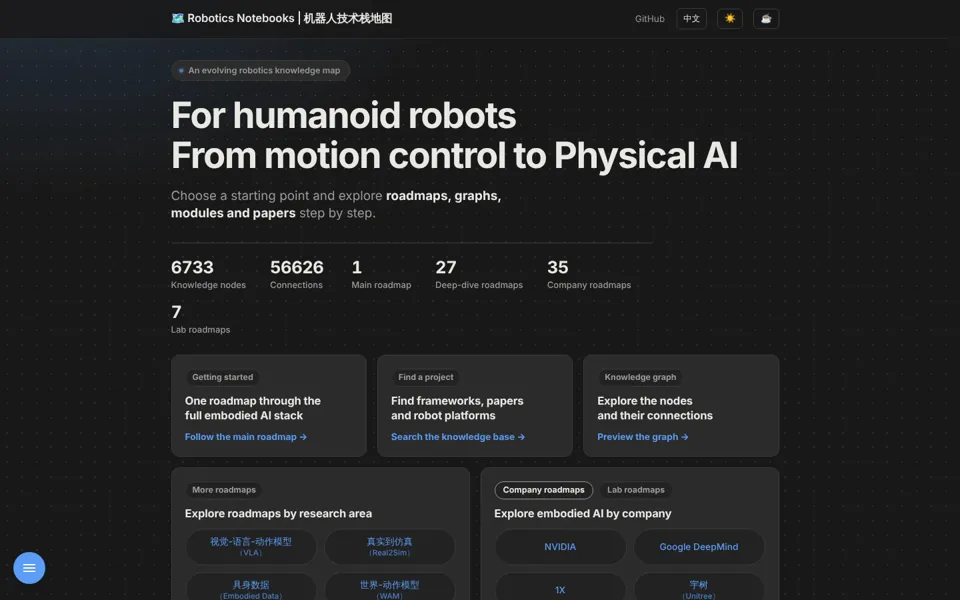
Robotics Notebooks
A knowledge map of robotics that enters through motion control and grows toward the full stack.
Visit Website →Hi there! I'm Chong Liu, a Robotics Engineer based in Shenzhen, China. I hold a master's degree in Mechanical Engineering from Columbia University, specializing in Robotics and Control.
I'm currently focused on humanoid robot reinforcement learning and imitation learning for motion control, working at BridgeDP Robotics Co., Ltd. to deliver customized motion control solutions for client humanoid robots.
I'm fascinated by designing and building advanced, life-like robots, and applying robotics technology to help people in need. This webpage contains my project documentation and resources to start on robotics from scratch. Together, let's make the world a better place!
A knowledge map of robotics that enters through motion control and grows toward the full stack.
Visit Website →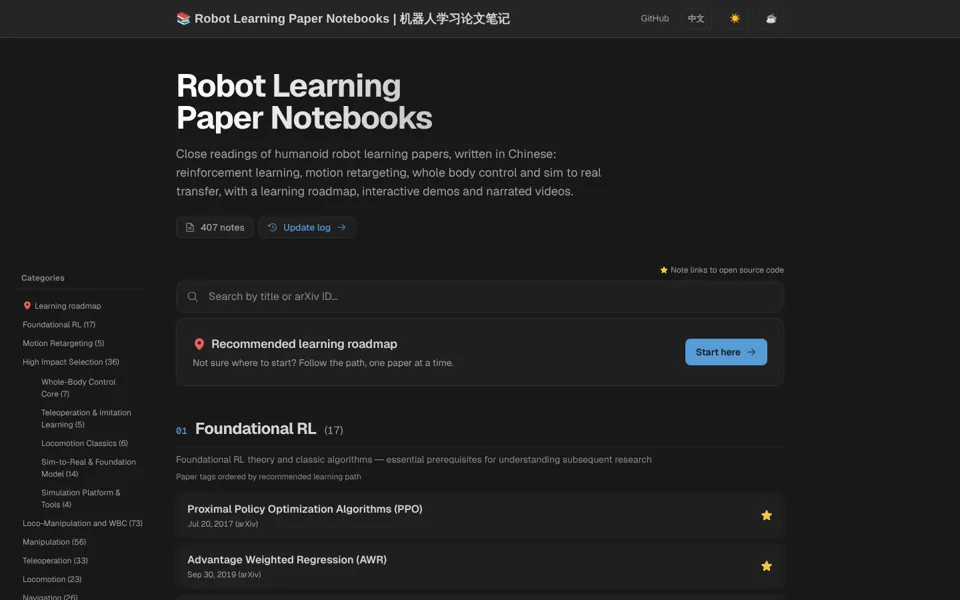
Reading notes on humanoid robot learning papers, from bipedal locomotion to whole-body control.
View Notes →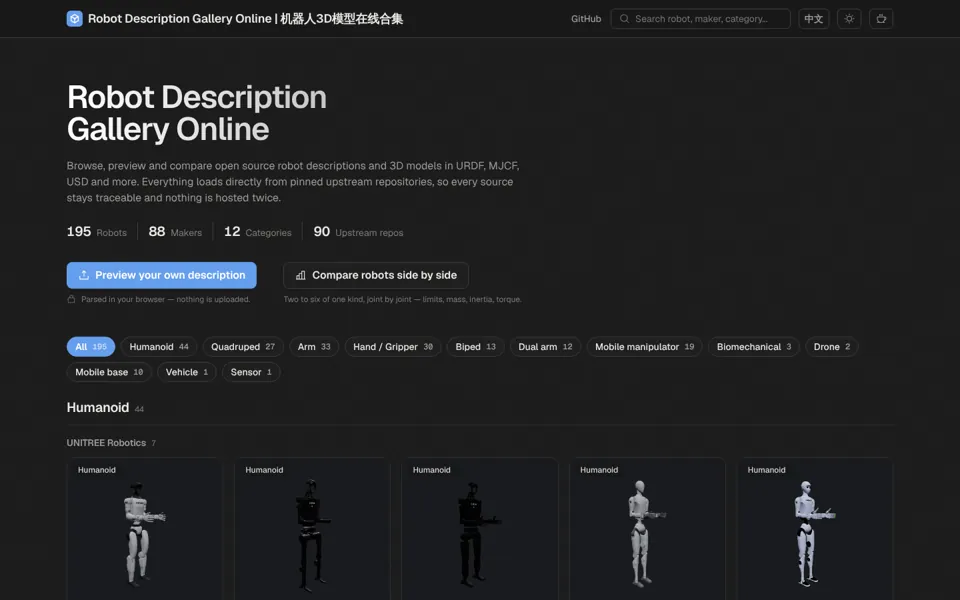
Browse and compare open robot models in the browser, or open your own description files.
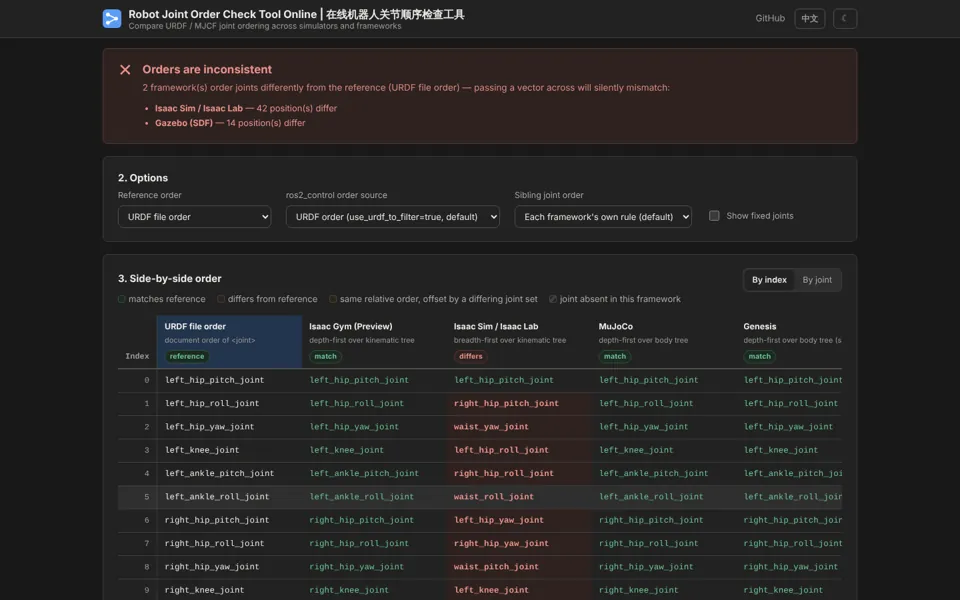
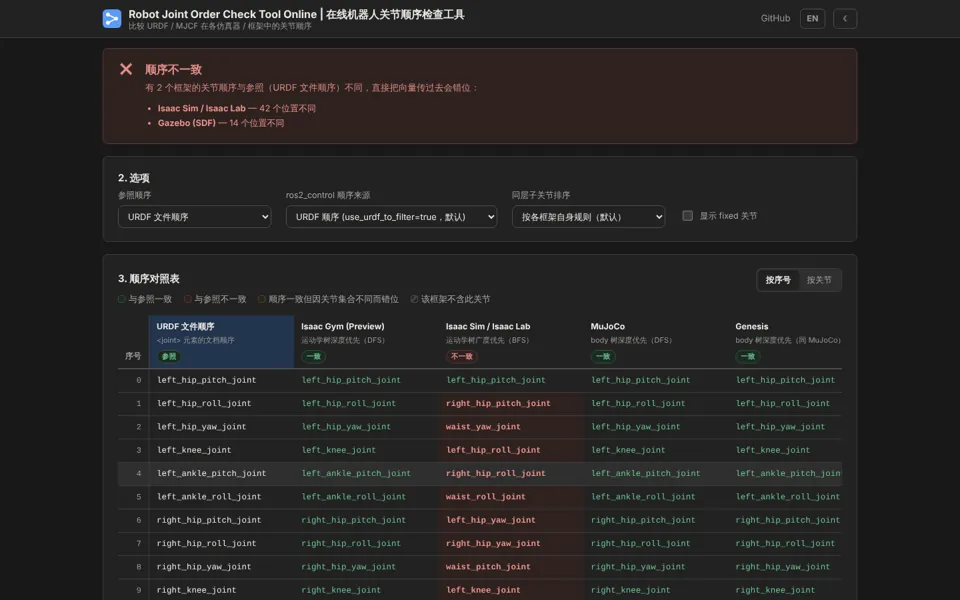
One URDF, many simulators: see where the joint order differs and get the index remap.
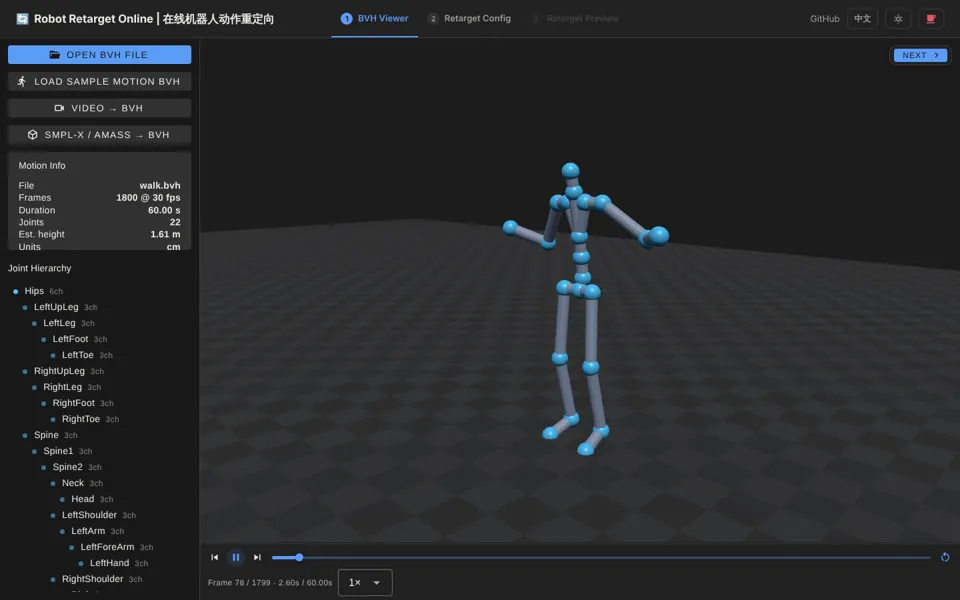
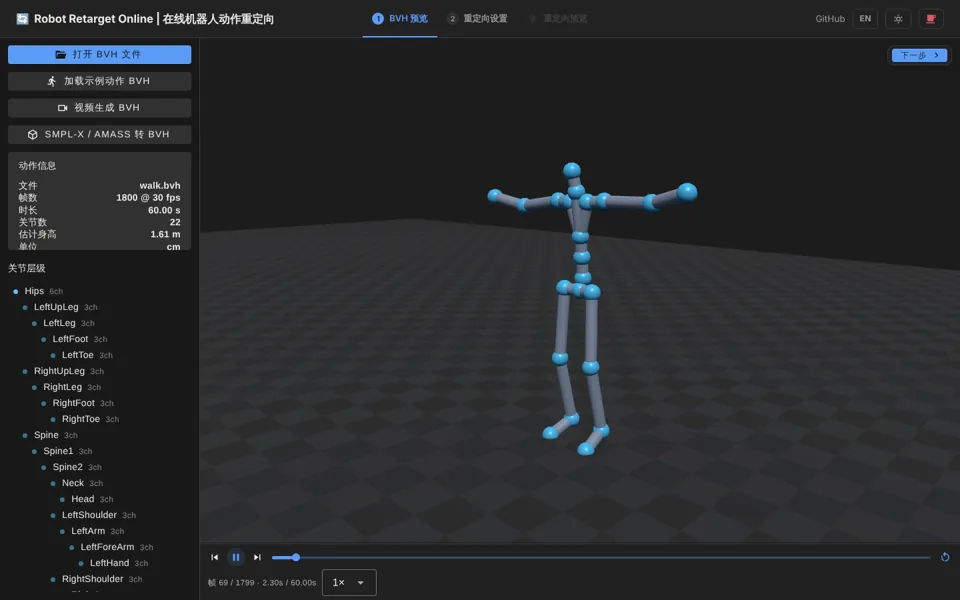
Retarget BVH mocap onto robots in the browser, with GMR ported to MuJoCo WebAssembly.
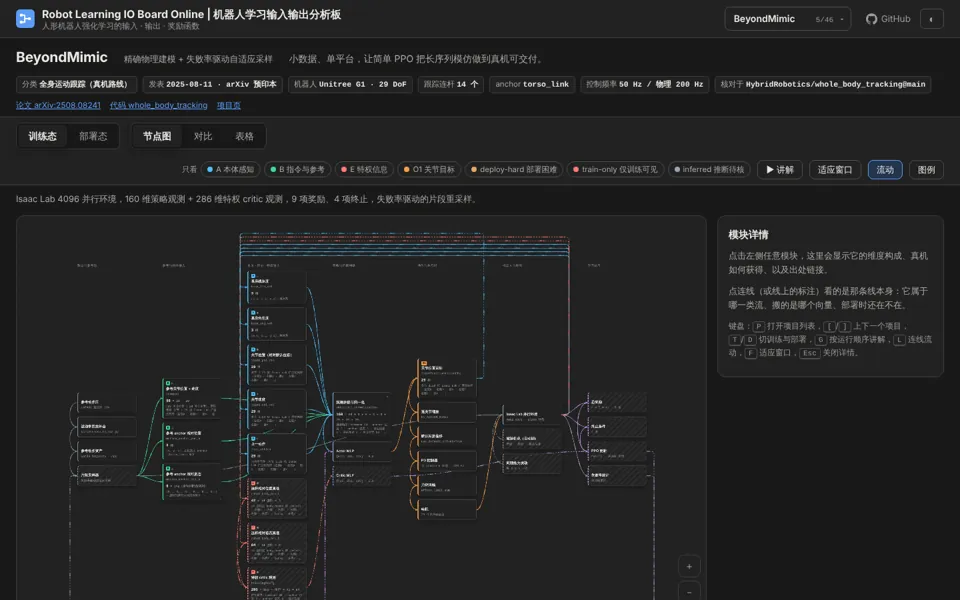
A node graph of what a humanoid policy observes, outputs and is rewarded for, traced to the upstream code.
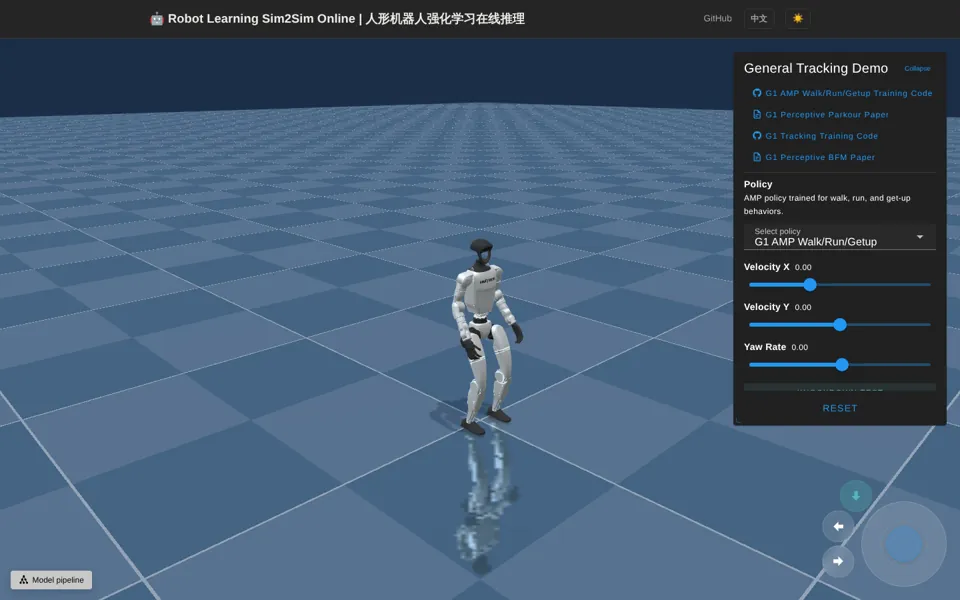
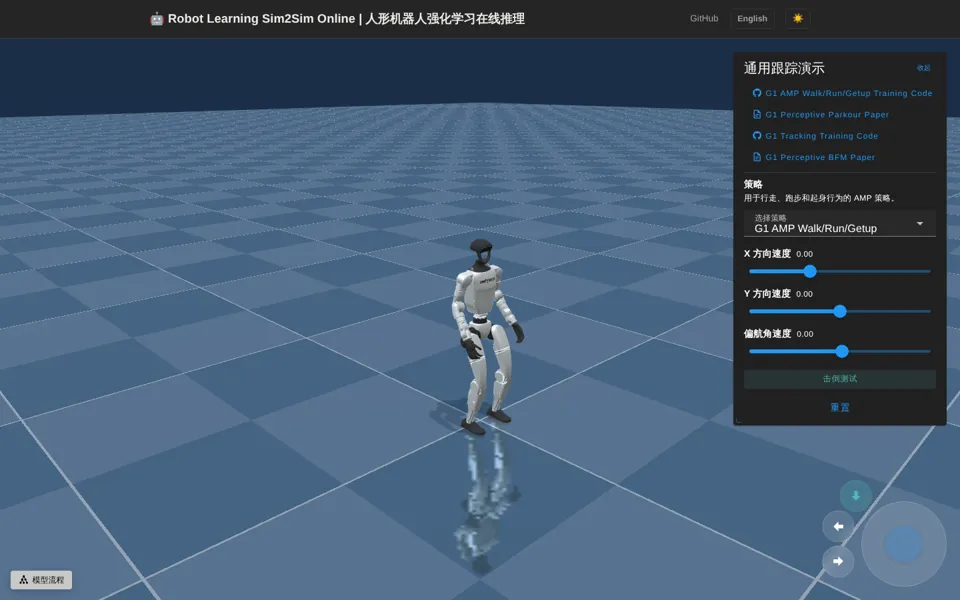
Run trained humanoid RL policies live in the browser, with no local install.
View Demo →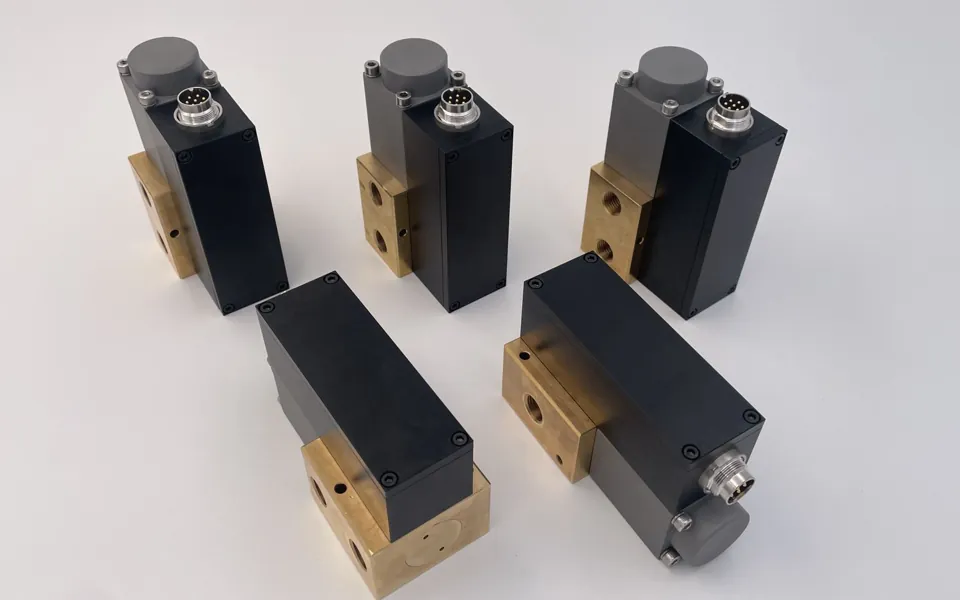
Designed and built a proportional valve for pneumatic systems, from CAD and tolerance analysis to testing.
View Project →Publications listed in reverse chronological order. See Google Scholar for citation details.
Cable-driven exoskeletons add minimal inertia and restrictions to the user's leg while still providing feedback and quantitative measures of the user's performance. This work proposes a Fourier analysis guided approach to reduce the number of actuated motors needed for cable-driven exoskeletons in walking assistance.
Google Scholar →Investigates the feasibility of machining high aspect ratio micro-through holes in Ti-6Al-4V titanium alloy using micro-EDM with silver nanopowder mixed dielectric for aerospace turbine blade cooling applications.
Google Scholar →Evaluates the micro-EDM machinability of Bulk Metallic Glass (BMG), assessing material removal rate, tool wear rate, surface quality, and dimensional accuracy for high aspect ratio micro-hole fabrication.
Google Scholar →Investigates the feasibility of machining micro-holes on non-conductive Aluminum Nitride ceramics using the "Assistive Electrode" micro-EDM process with multi-layer conductive coatings.
Google Scholar →Investigates the machinability of Bulk Metallic Glass using micro-EDM, evaluating crater sizes and overcut of micro-holes through experimental investigation and numerical simulation.
Google Scholar →Explores the Assisting Electrode Method as a solution for machining non-conductive Aluminum Nitride ceramics using powder mixed micro-EDM process.
Google Scholar →Comprehensively discusses optimization techniques — Taguchi robust design, grey relational analysis, genetic algorithm, and neural network — for Electric Discharge Machining based processes.
Google Scholar →Provides a concise overview of the micro-wire-electro-discharge machining (micro-WEDM) process, covering process mechanism, system components, parameters, variants, and innovative applications.
Google Scholar →On this meaningful day, I registered my marriage with my beloved wife.
你好呀!我是刘冲,现任职于广东深圳,从事机器人工程师工作。我毕业于哥伦比亚大学机械工程专业,专攻机器人与控制方向。
我目前就职于桥介数物(深圳)科技有限公司,专注于人形机器人的强化学习与模仿学习运动控制算法研究,为客户的人形机器人提供定制化运动控制算法解决方案。
我着迷于设计、建造先进精妙逼真的机器人,并应用机器人技术来帮助有需要的人。该网页包含我创建项目的文档和学习资源,让所有人都可以从零开始研究机器人技术。让我们一起,让世界变得更美好!
论文按时间倒序排列,引用详情见 Google Scholar。
提出基于傅里叶分析的绳驱外骨骼执行器设计方法,以减少行走辅助所需的驱动电机数量,降低穿戴设备的复杂度。
Google Scholar →研究使用银纳米粉末混合微电火花加工在钛合金 Ti-6Al-4V 上加工高深宽比微孔的可行性,应用于航空涡轮叶片冷却孔制造。
Google Scholar →评估块体金属玻璃(BMG)的微电火花可加工性,考察材料去除率、刀具磨损率、表面质量和尺寸精度。
Google Scholar →研究利用辅助电极微电火花工艺在非导电氮化铝陶瓷上加工微孔的可行性,采用多层导电涂层实现高深宽比微孔加工。
Google Scholar →通过实验与数值模拟研究块体金属玻璃的微电火花可加工性,重点评估微孔的弧坑尺寸和过切量。
Google Scholar →探索辅助电极方法用于粉末混合微电火花加工非导电氮化铝陶瓷的方案。
Google Scholar →综合讨论田口稳健设计、灰色关联分析、遗传算法和神经网络等优化技术在电火花加工中的应用。
Google Scholar →在这个重要的日子里,我和亲爱的夫人完成了结婚登记。